RESEARCH & PUBLICATIONS

Thinking in the long term.

PUBLICATIONS

Robotics, data collection, and learning from human guidance.
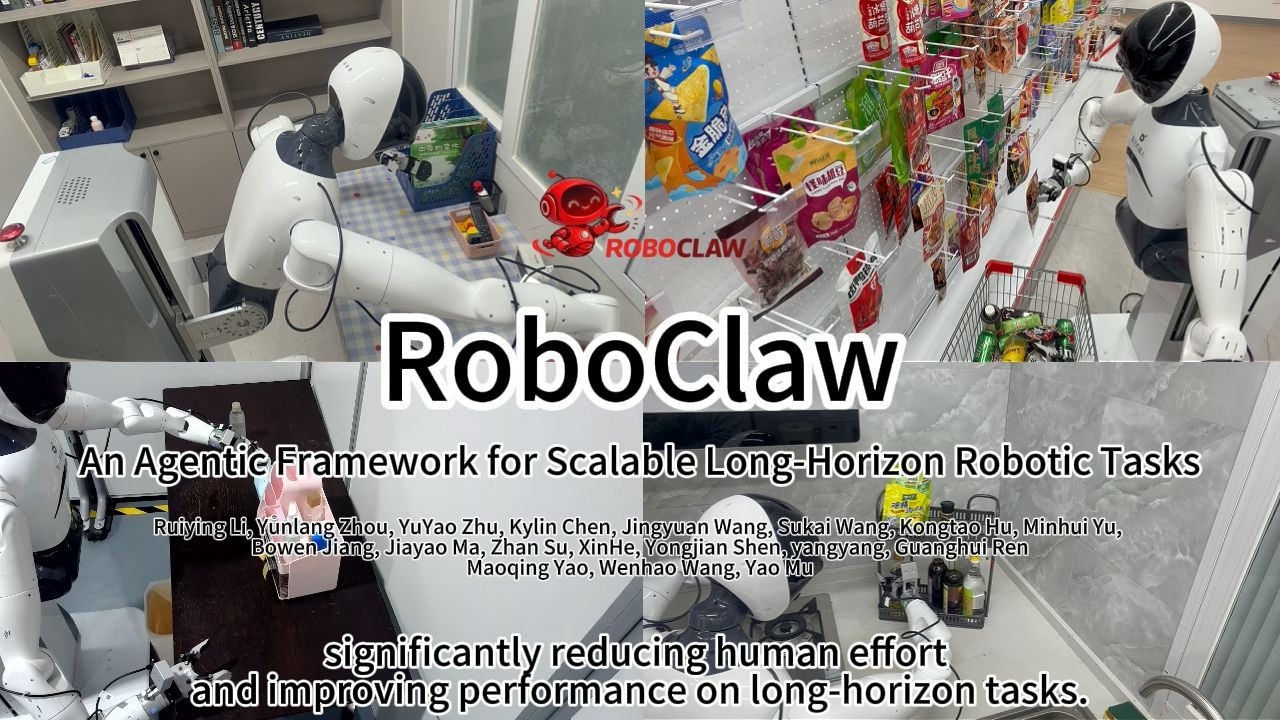
RoboClaw: An Agentic Framework for Scalable Long-Horizon Robotic Tasks — research overviewRoboClaw

ECCV · 2026

RoboClaw: An Agentic Framework for Scalable Long-Horizon Robotic Tasks

Ruiying Li, Yunlang Zhou, Yuyao Zhu, Kylin Chen, Jingyuan Wang, Sukai Wang, Kongtao Hu, Minhui Yu, Bowen Jiang, Zhan Su, Jiayao Ma, Xin He, Yongjian Shen, Yang Yang, Guanghui Ren, Maoqing Yao, Wenhao Wang†, Yao Mu†

† Co-corresponding authors

A unified agent loop connects data collection, policy learning, and long-horizon robot execution.

FieldGen

arXiv

FieldGen: From Teleoperated Pre-Manipulation Trajectories to Field-Guided Data Generation

Wenhao Wang*, Kehe Ye*, Xinyu Zhou*, Tianxing Chen*, Cao Min, Qiaoming Zhu, Xiaokang Yang, Ping Luo, Yongjian Shen, Yang Yang, Maoqing Yao, Yao Mu

* Equal contribution

Field-guided trajectory generation combines diverse robot approaches with precise human demonstrations.

Genie Centurion

arXiv

Genie Centurion: Accelerating Scalable Real-World Robot Training with Human Rewind-and-Refine Guidance

Wenhao Wang*, Jianheng Song*, Chiming Liu*, Jiayao Ma, Siyuan Feng, Jingyuan Wang, Yuxin Jiang, Kylin Chen, Sikang Zhan, Yi Wang, Tong Meng, Modi Shi, Xindong He, Guanghui Ren, Yang Yang, Maoqing Yao

* Equal contribution

Human rewind-and-refine guidance enables corrective data collection and one-person-to-many-robots supervision.
AgiBot World Colosseo: A Large-scale Manipulation Platform for Scalable and Intelligent Embodied Systems — research overviewAgiBot World
IROS · 2025

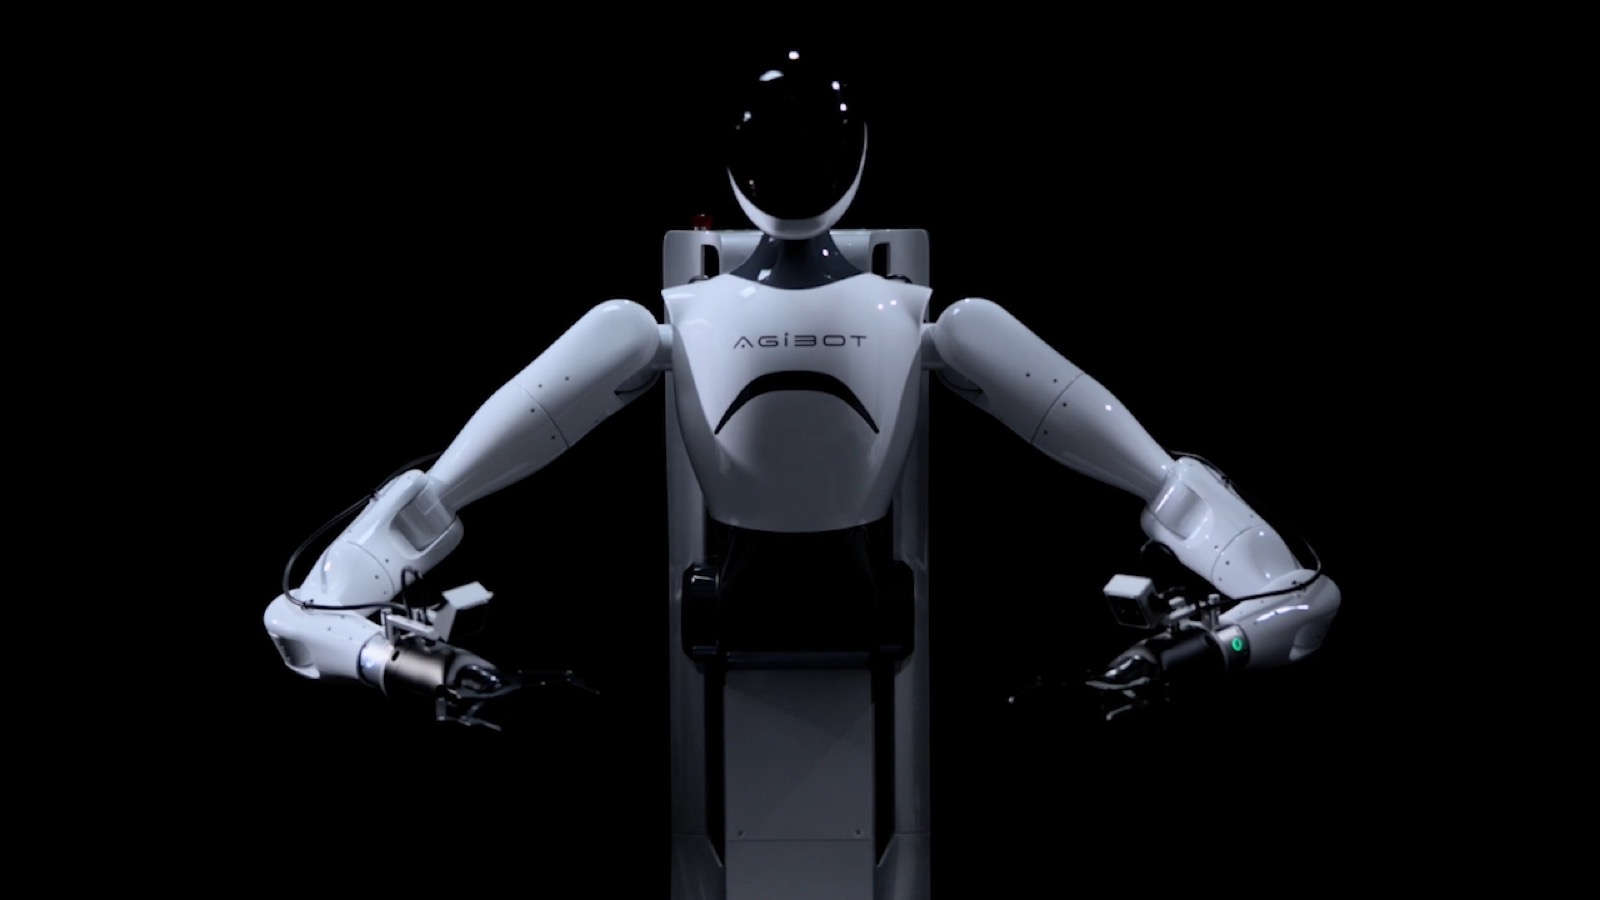
AgiBot World Colosseo: A Large-scale Manipulation Platform for Scalable and Intelligent Embodied Systems

AgiBot-World Contributors

A large-scale real-world manipulation platform and dataset for scalable embodied learning.

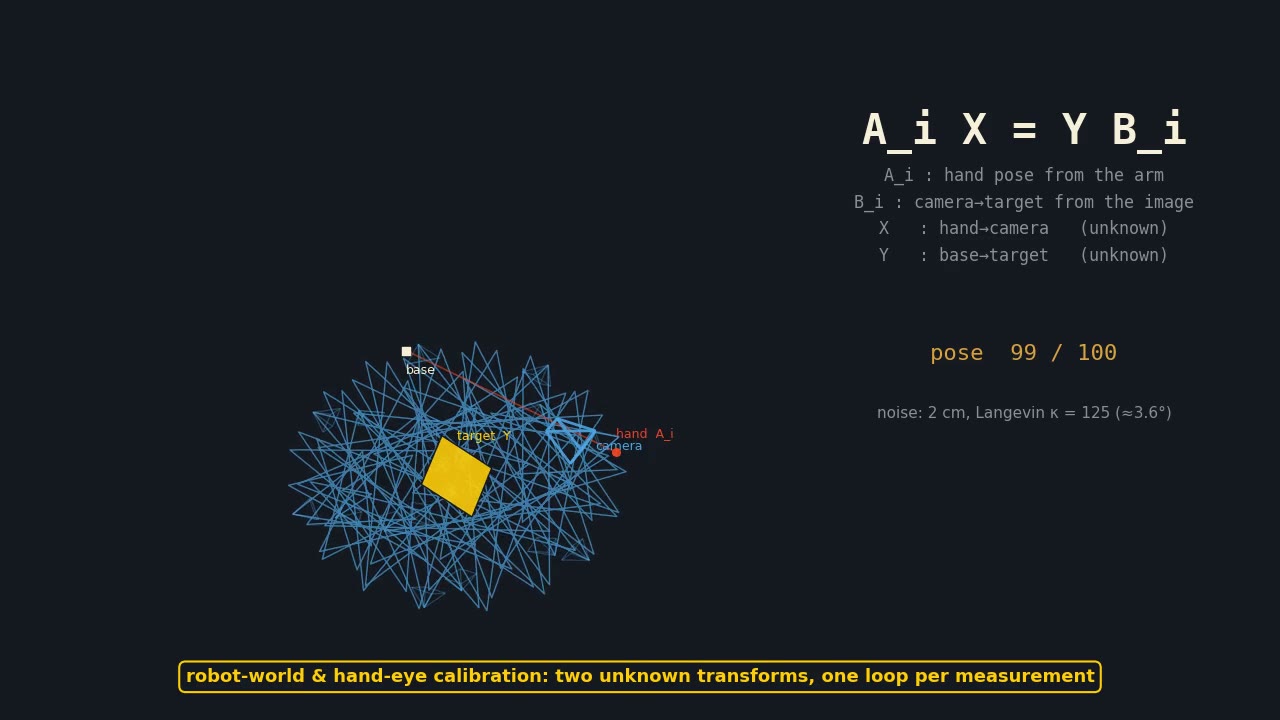
A Certifiably Correct Algorithm for Generalized Robot-World and Hand-Eye Calibration — research overviewCertified calibration

The International Journal of Robotics Research · 2026

A Certifiably Correct Algorithm for Generalized Robot-World and Hand-Eye Calibration

Emmett Wise, Pushyami Kaveti, Qilong Cheng, Wenhao Wang, Hanumant Singh, Jonathan Kelly, David M. Rosen, Matthew Giamou

Certifiably globally optimal calibration for multiple sensors and targets, including monocular cameras with unknown scale.