Wenhao Wang(王文灏)
Currently at AgiBot
Teleop Team FounderThe Youngest Tech Lead
I led the development of the control systems behind AgiBot’s Genie-series robots. I built the teleoperation system and team from scratch, then scaled deployment to thousands of robots, collecting over 200,000 hours of real-world robot data and supporting 1 million hours of robot operation. Building on this work, AgiBot World has earned over 3,000 GitHub stars and accumulated over 2 million downloads on Hugging Face.
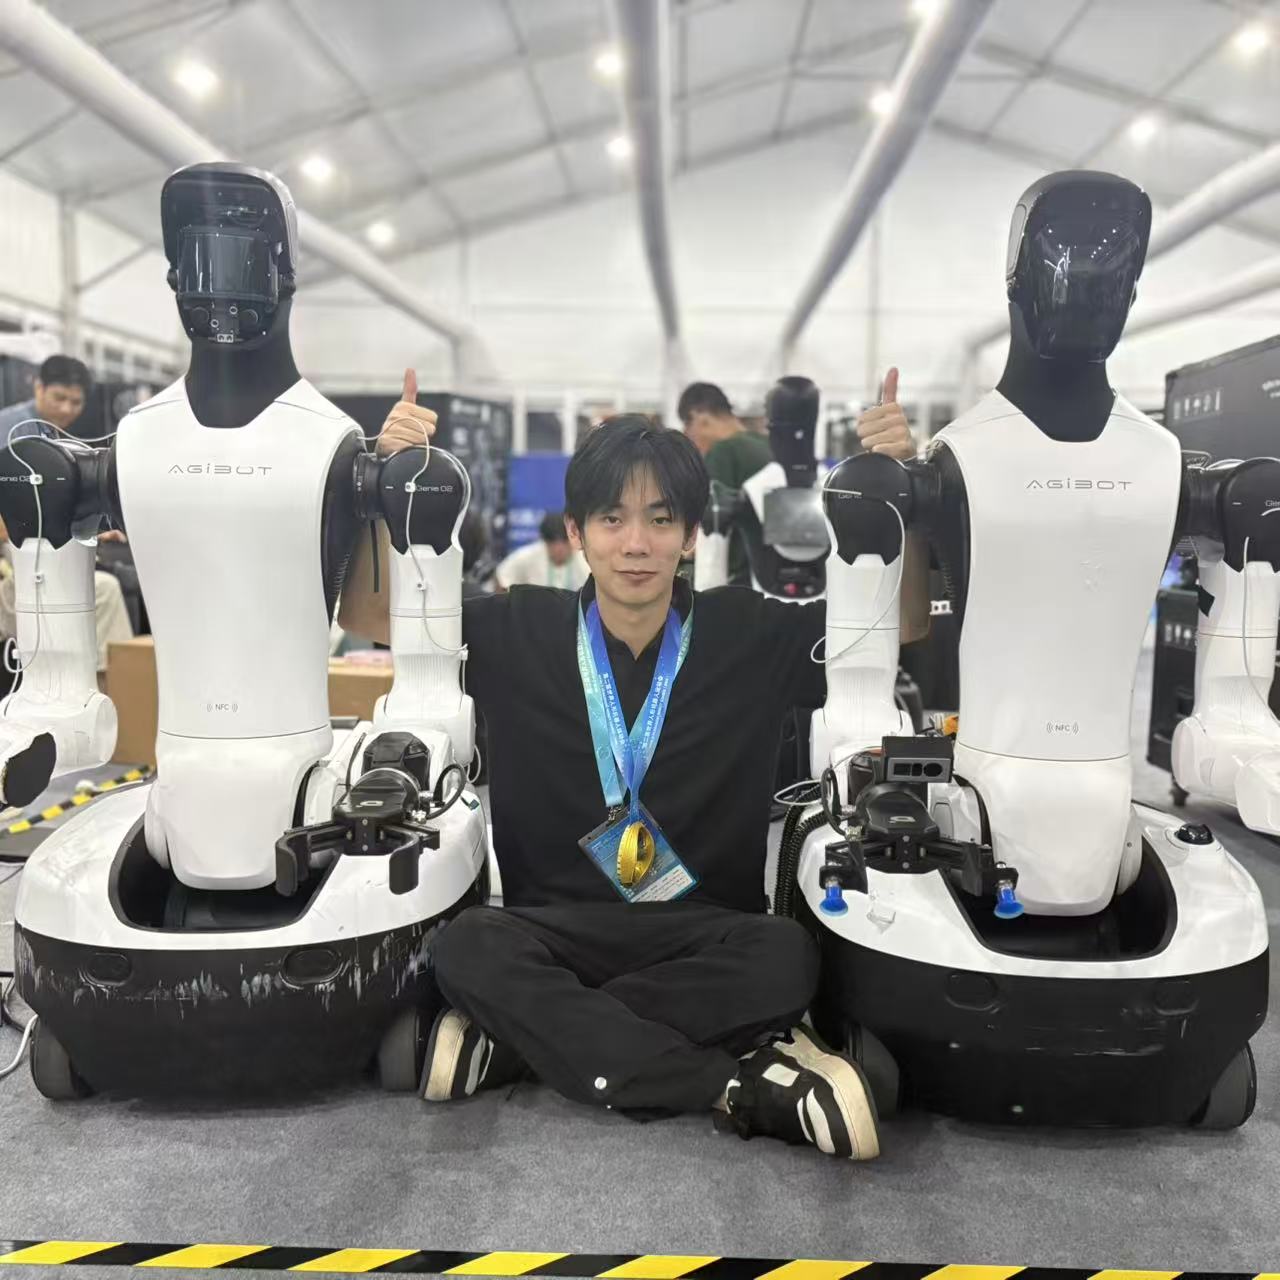
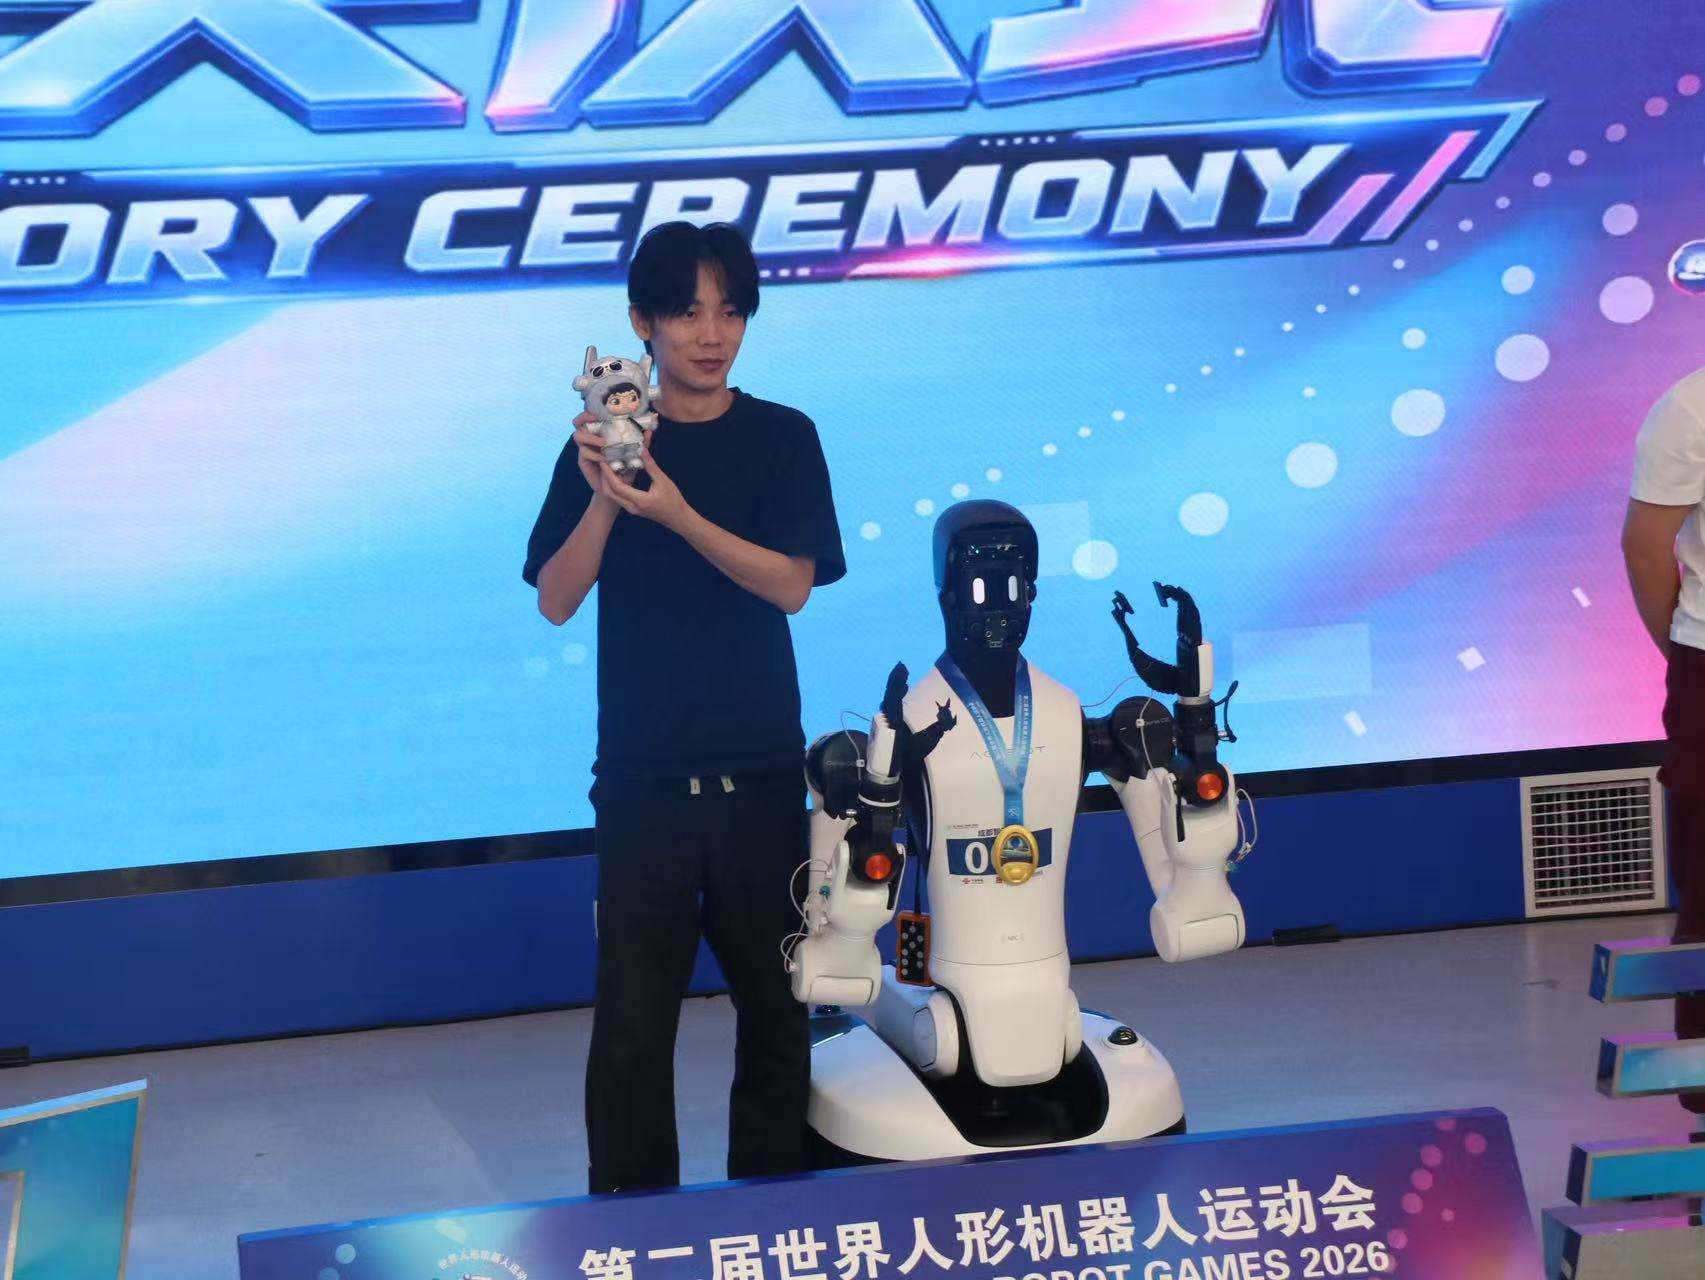
My team developed RoboClaw, one of the earliest agentic systems for real-world manipulation. We subsequently extended this work into reusable robot skills and rapid task deployment, winning 3 gold medals in the scenario-based events at the 2026 World Humanoid Robot Games.
我主导了智元 Genie 系列机器人的控制系统研发和产品化。我在 0~1 阶段,搭建遥操作系统与团队,1~100 阶段,将系统规模化部署到千台机器人集群,累计采集超过 20 万小时真机数据,支撑百万小时机器人运行。在此基础上,AgiBot World 获得了超过 3,000 GitHub Stars,并在 Hugging Face 累计超过 200 万次下载。
我的团队开发了 RoboClaw,是业内最早面向真实世界操作任务的 Agentic 系统之一。随后,我们将这一工作拓展为可复用的机器人技能与快速任务部署能力,在 2026 年世界人形机器人运动会场景赛中获得 3 枚金牌。
AUGUST 2026 · RECENT HIGHLIGHT
World Humanoid Robot Games
At the 2026 World Humanoid Robot Games, I led the Real-World Manipulation Team to 3 gold, 4 silver, and 4 bronze medals, including a sweep of the industrial podium. Building on RoboClaw, we developed Genie Studio Agent for rapid industrial deployment through reusable robot skills. Our entries combined fully autonomous execution with hybrid workflows, where humans handled only selected steps. Both used the same planning, skill, and data collection stack, enabling a gradual transition toward autonomy as corrective data accumulated. All entries used production robots and software.
在 2026 年世界人形机器人运动会上,我带领真机操作团队获得 三金、四银、四铜,并包揽工业赛道金银铜。在 RoboClaw 的基础上,我们开发了 Genie Studio Agent,通过可复用的机器人技能实现工业场景的快速部署。参赛方案涵盖全自主执行与人机混合流程,后者仅由人工处理部分步骤。两种模式共用规划、技能执行与数据采集技术栈,随着纠正数据的积累,逐步向自主执行过渡。所有参赛机器人及软件均为量产版本。
JULY 2026 · RECENT HIGHLIGHT
Scalable Teleoperation for Real-World Robots Training
The core engineering work of the team I founded and lead at AgiBot.
A production control system deployed across thousands of robots, supporting 1 million hours of robot operation and connecting real-world task execution, human intervention, data feedback, and model training into a scalable deployment loop. Cross-city teleoperation at near-human speed, supporting real-world data collection across AgiBot World’s five thematic areas.
面向数千台机器人集群的量产控制系统,支撑累计 100 万小时机器人运行,将真实任务执行、人工接管、数据回流与模型训练连接为可规模化交付的闭环。接近人类操作速度的跨城市遥操作,支撑 AgiBot World 五大主题的真实场景数据采集。
Systems, real-world deployments, and technical details.
A LITTLE ABOUT ME
At the intersection
of humans
and machines.
About me
I am currently working at AgiBot. My focus is on deploying robots in factory environments to collect real-world data. The ultimate goal is to develop a human-in-the-loop control system that integrates teleoperation with learning-based autonomy, empowering humans with mechanical bodies that exceed natural physical limitations.
Before that, I had a startup company, SOMA, aiming to build the best and user-friendly teleoperation and data collection system for robots. I was working at GRASP Lab, University of Pennsylvania (UPenn), with Prof. Nadia Figueroa and Prof. Mark Yim, during my robotics master study. I completed my bachelor’s degree in Mechanical and Automation Engineering at The Chinese University of Hong Kong (CUHK).
Hobbies
One of my favorite activities is playing Mafia (The Werewolves of Millers Hollow, 狼人杀). I view it not merely as a logic game but as a psychological and dramatic performance. Logic is just one avenue to persuade (or “influence”, or perhaps, “c-h-e-a-t”) others; there are many other aspects to explore within the game, such as different players, game settings, and the intricacies of psychology. The brilliance of this game lies in the psychological warfare.
I fell in love with Poker after learning probability and statistics. This game is not about gambling, but about self-discipling.